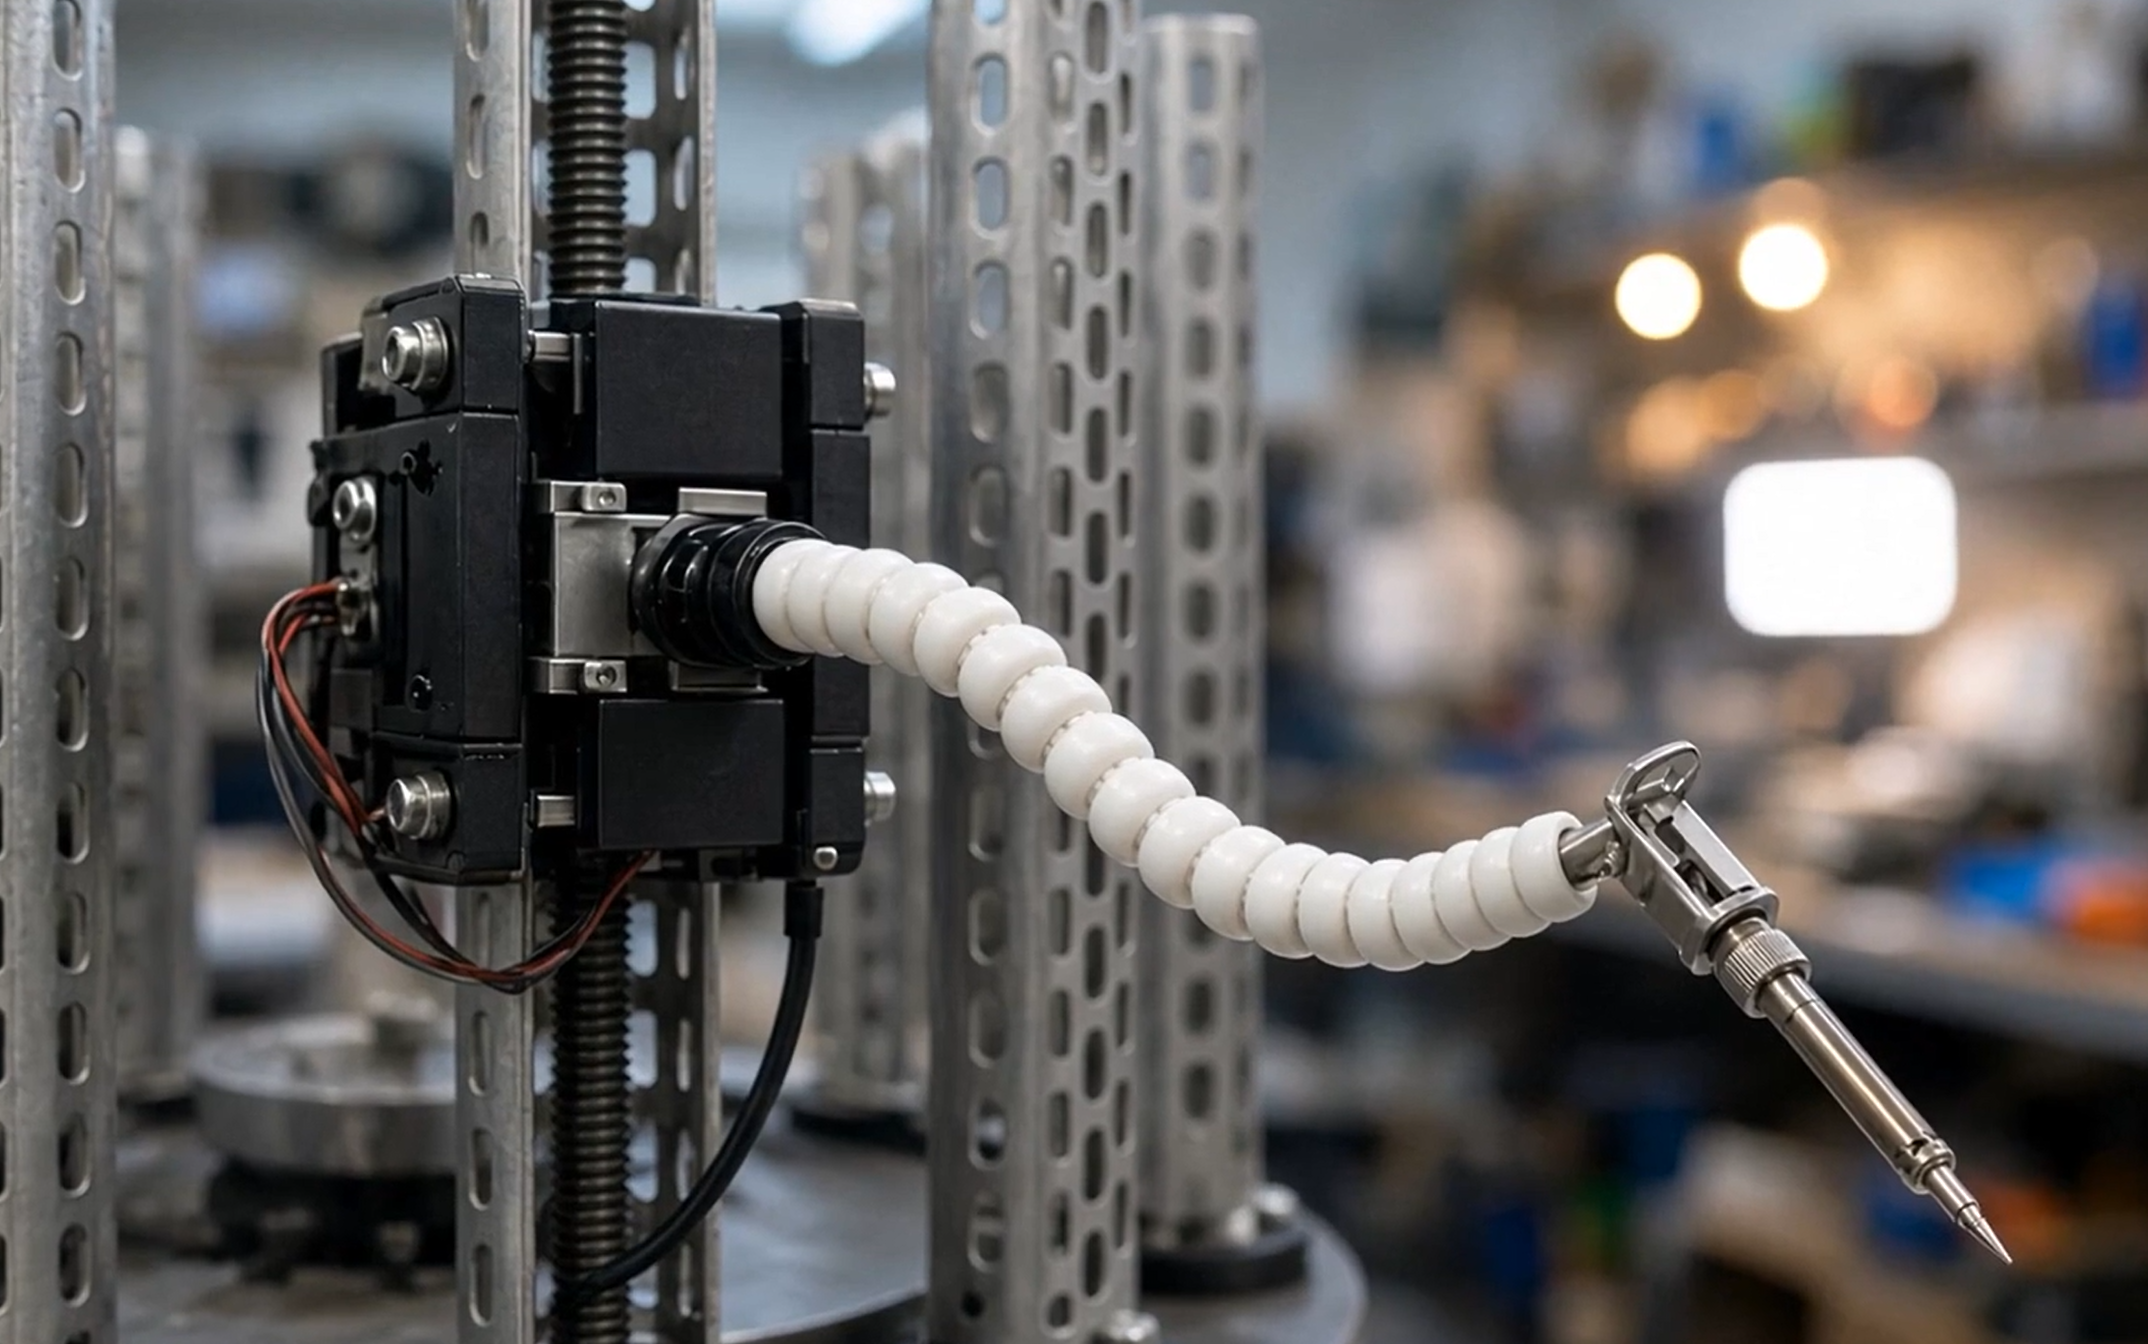
Flexible tentacles
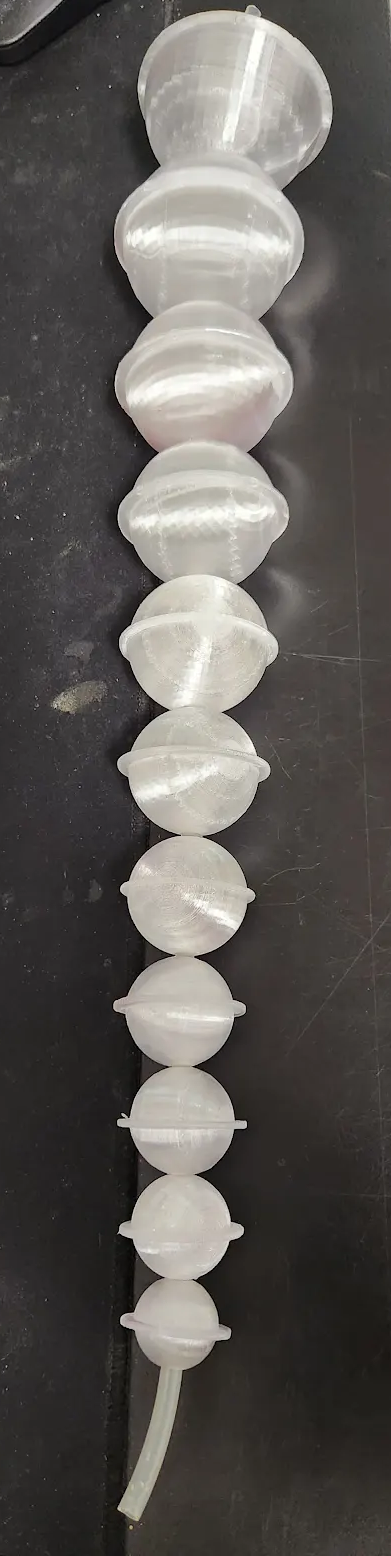
Chains of lightweight, hollow printed elements are being tested as adaptable arms for cameras, tools and other end devices.
Telepresence / Robotics / Open Development
A modular mobile robot for remote collaboration and hands-on experimentation.
Hero image: concept visualizationThe project
Hynebot is an open-source telepresence robotics project created by Jamie Hyneman in collaboration with Novation Tech LLC.
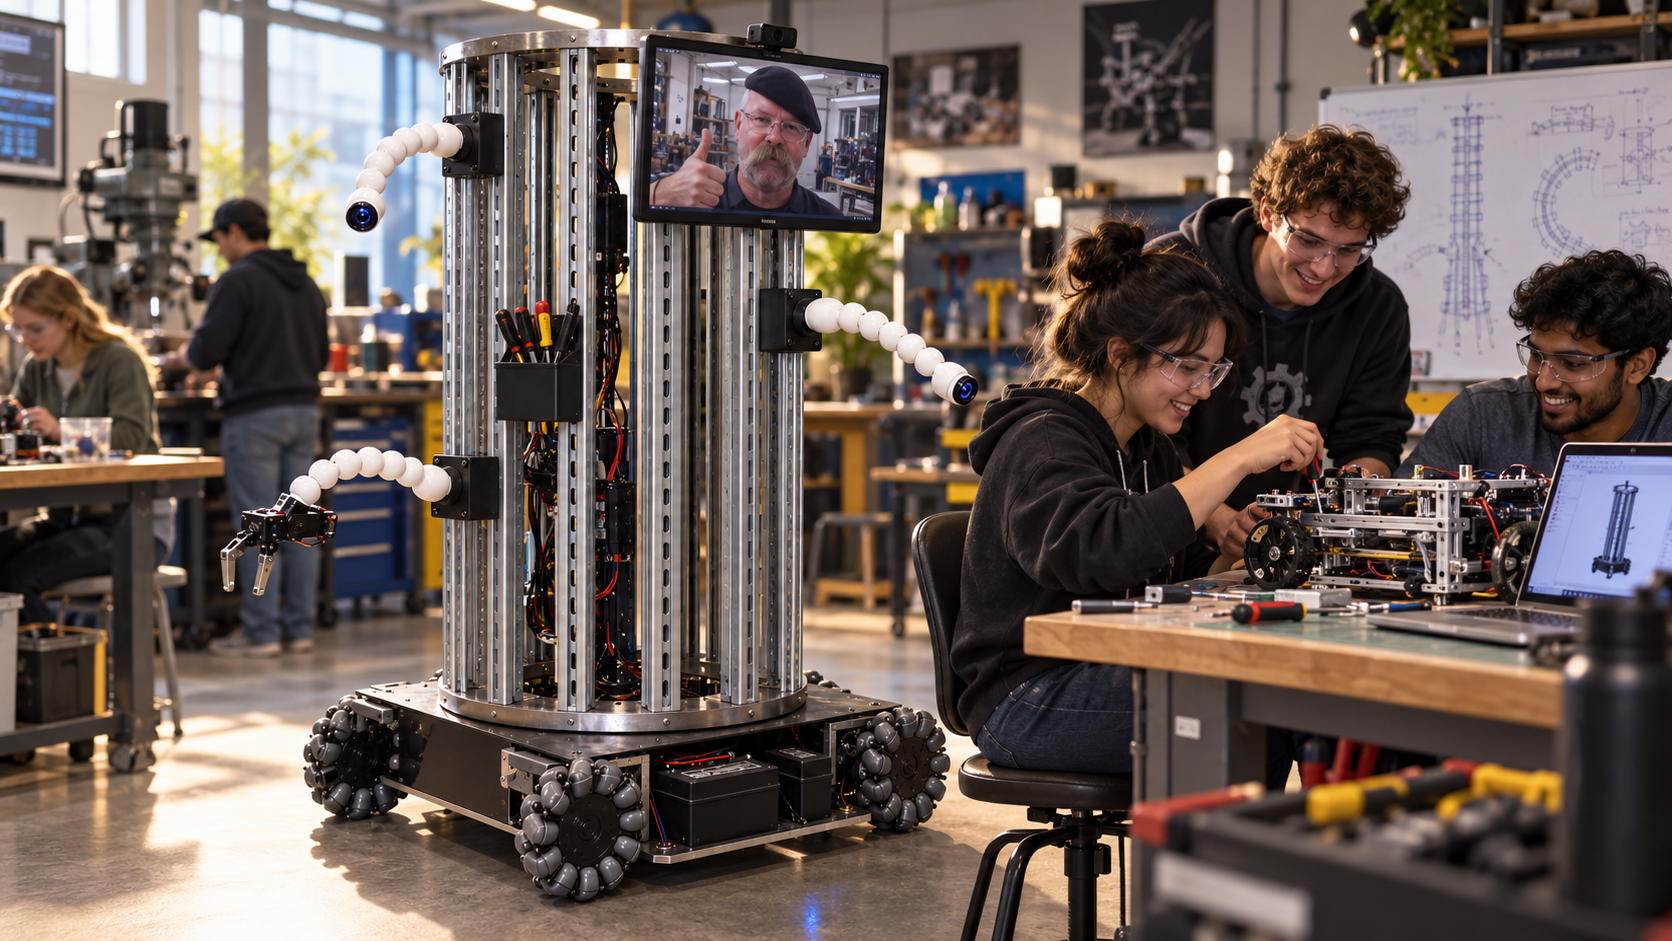
The project explores how a mobile robot can provide more than a camera and screen. The intended platform combines an omnidirectional base with twelve vertical structural tracks that can carry cameras, sensors, flexible arms and other interchangeable devices.
Individual mechanisms can be developed and tested away from the robot, then integrated onto the shared platform. This modular approach allows several experiments to progress in parallel while keeping the core robot available.
Novation is helping to develop prototype tentacle mechanisms, vertical trolley and lifting systems, control software and test hardware.
Concept visualization
This visualization presents the intended direction of Hynebot. It includes imagined scenes and capabilities; it is not footage of a completed robot.
Concept visualization. Jamie Hyneman appears with permission; other people and workshop scenes shown here are AI-generated.
Novation’s contribution
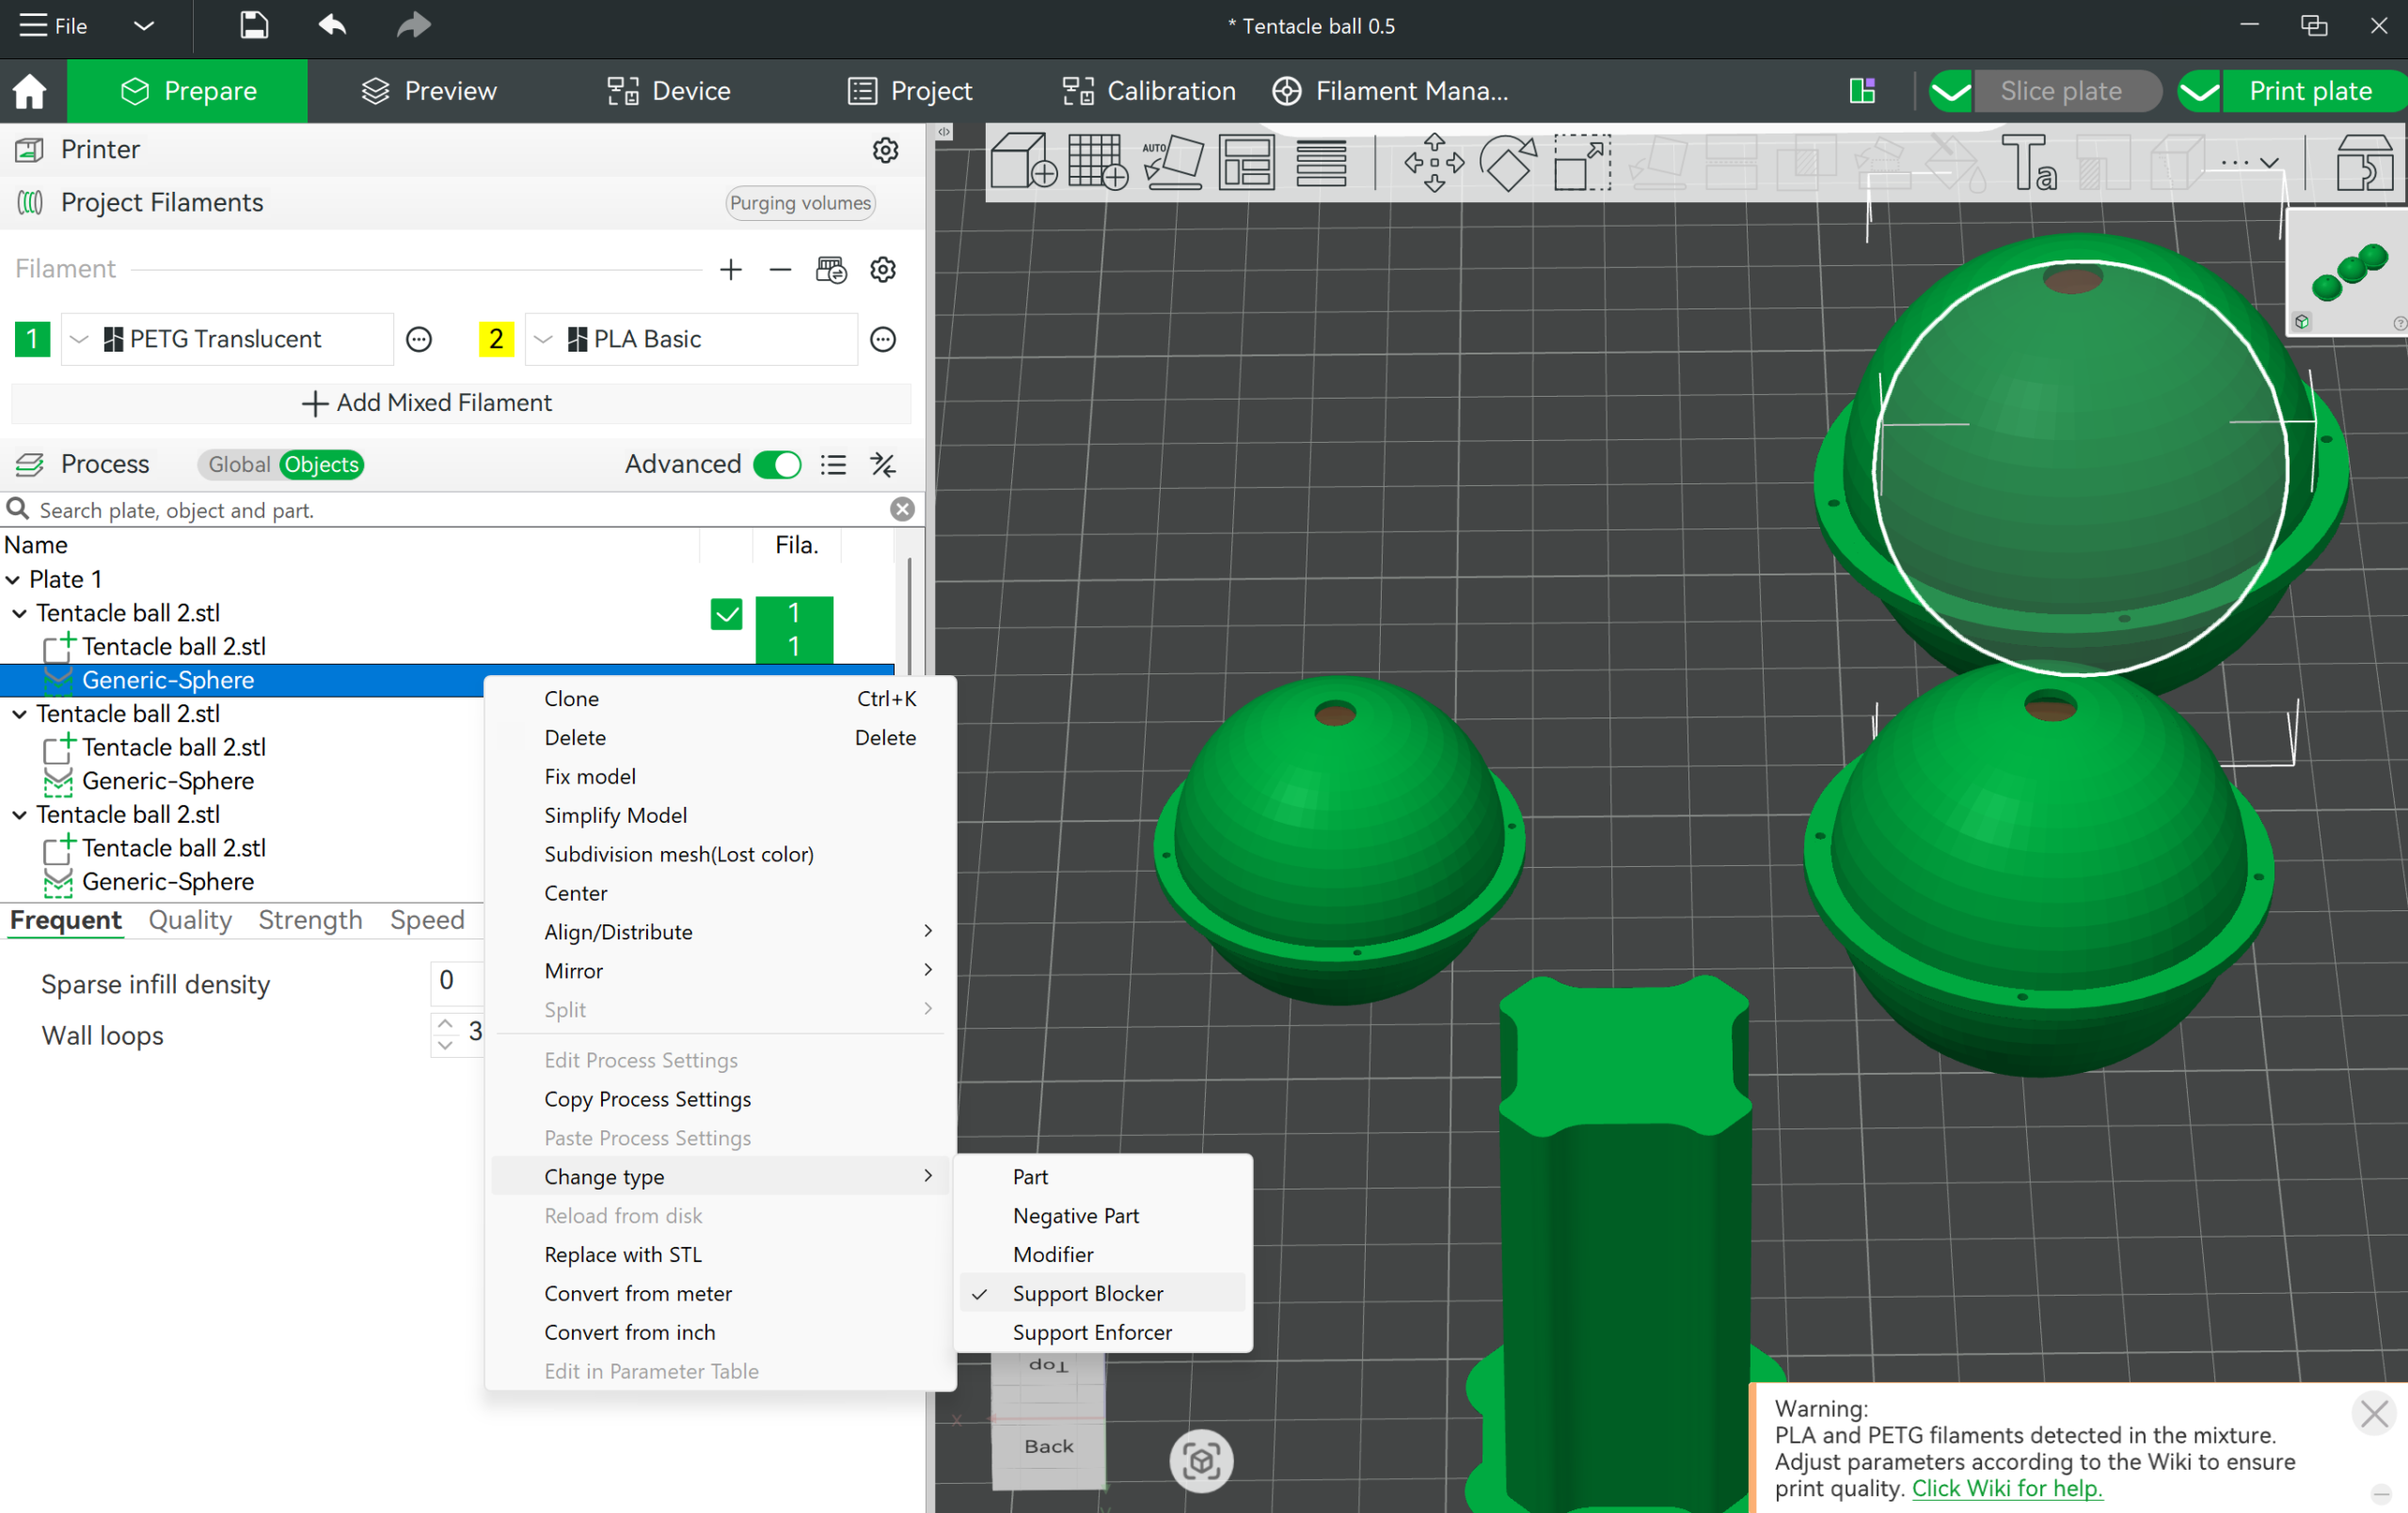
Chains of lightweight, hollow printed elements are being tested as adaptable arms for cameras, tools and other end devices.
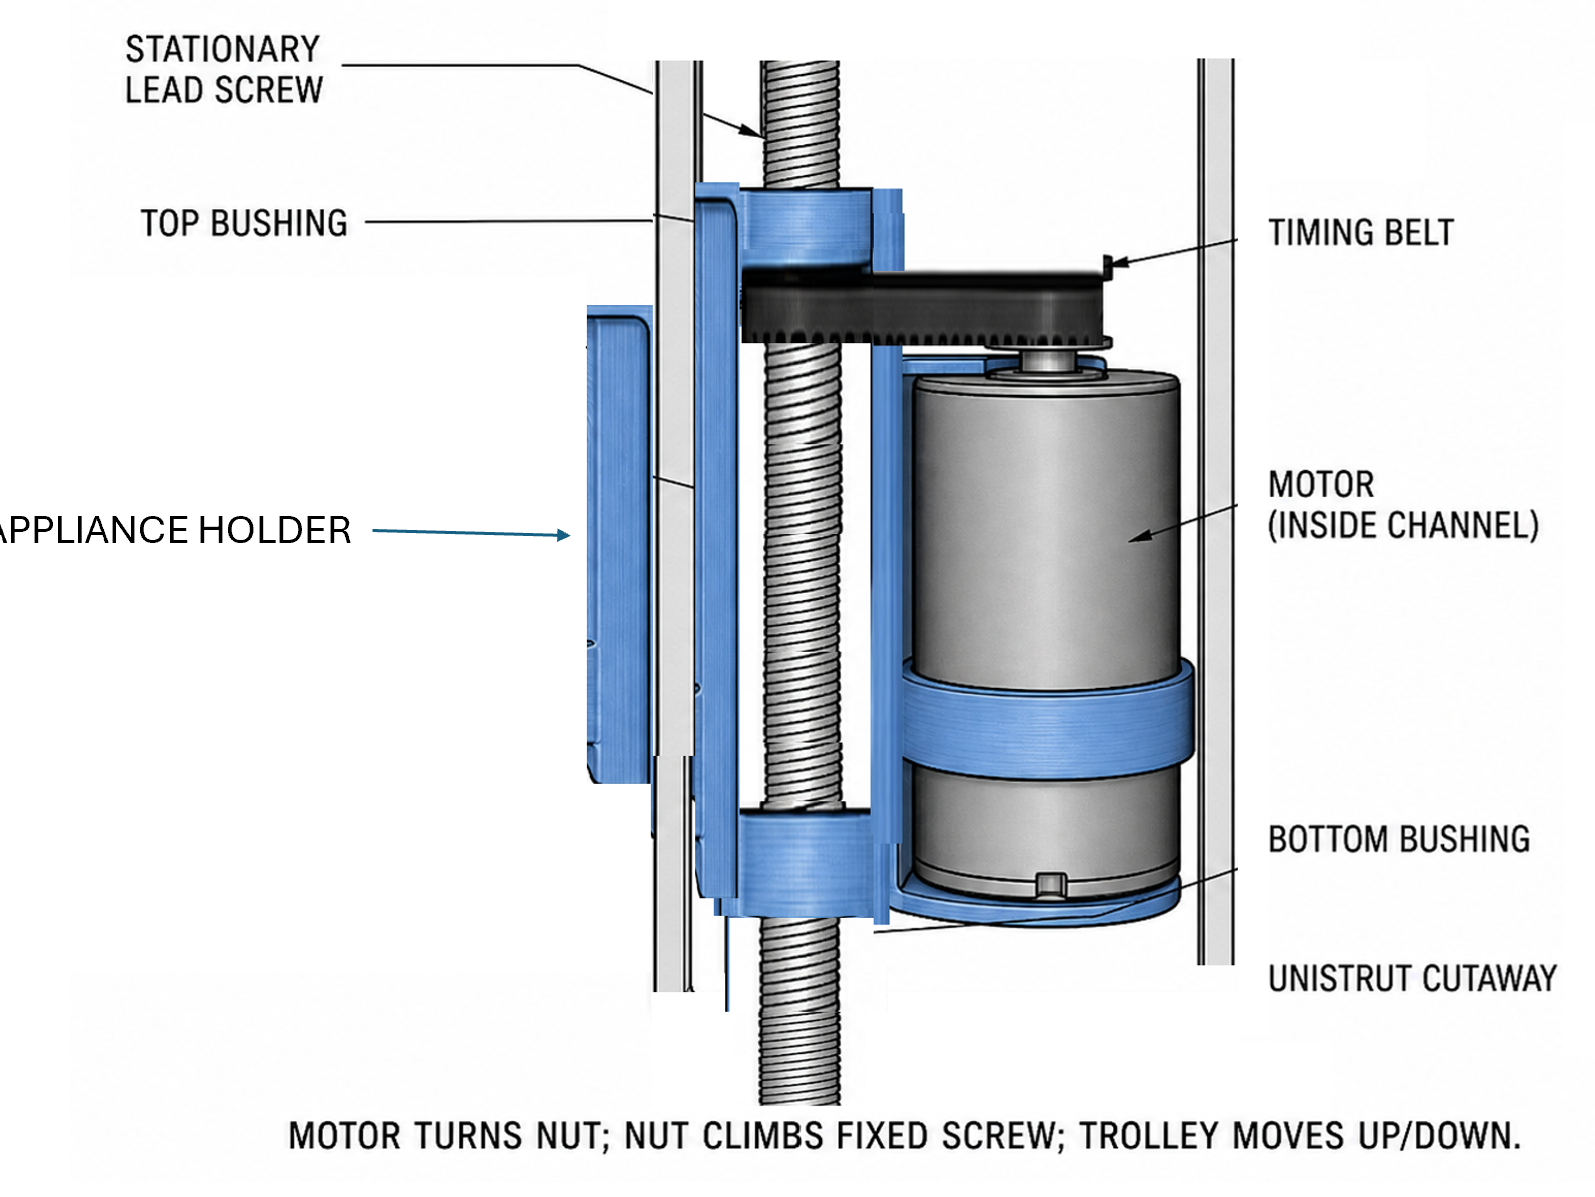
A compact trolley and lifting concept uses structural channel, a stationary lead screw and a movable carriage to position equipment vertically.
Bench software and hardware tests help turn individual motors, servos and mechanisms into repeatable systems that can be refined safely.
From design to hardware
Exploring possible interactions
Open development
Hynebot remains a work in progress. Designs, controls and mechanisms will continue to change as prototypes are built and tested. The project is intended to be shared as open source as development matures.
Images labeled “concept visualization” are AI-generated representations of project ideas. Photographs and software screenshots are identified separately.
Connect with Novation